Regrip panel
The Regrip panel allows you to configure and manage the regripping operations for a part held by the robot gripper. Click twice on the R1, R2.. cells in the bend navigator to open the Regrip panel or click on the part held by the robot gripper at the regrip position.
Method
The following are the methods of regripping a part:
-
Clamp
-
During Bend
-
Post-Bend
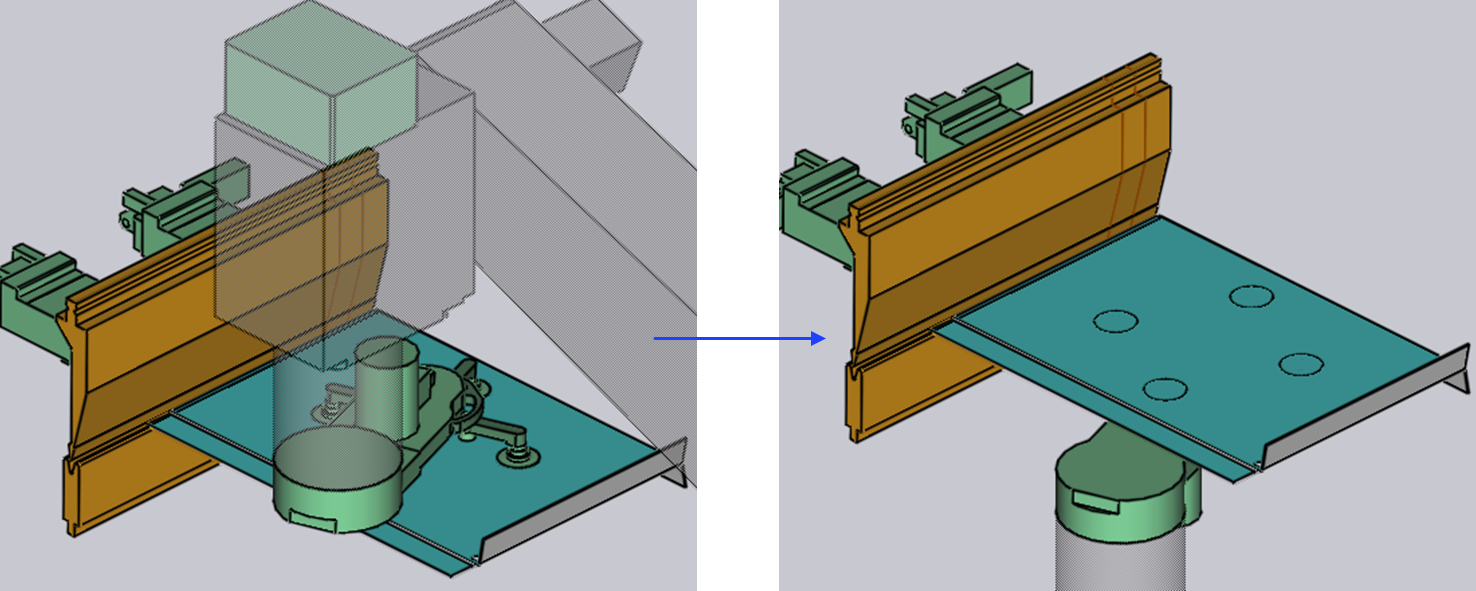
Clamp
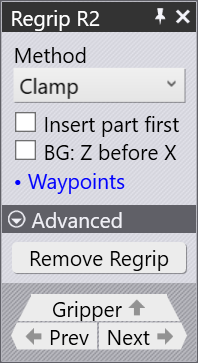
When the Clamp method is selected, the gripper relies on the bending tool (punch and die) to hold the part, complete the swivel sequence and then re-grips from the other side of the part.
Insert part first and BG: Z beforeX: These options appears when Clamp method is selected. Refer Insertion strategy for more details about these options.
During Bend
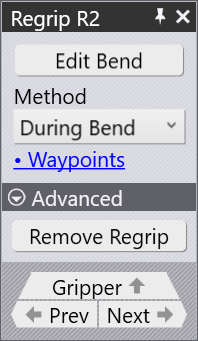
When the During Bend method is selected, as soon as the bending operation starts the gripper starts to swivel simultaneously (if required) and performs the regripping exactly at the end of the bending operation.
Opening of the punch starts only when the part is firmly held by the robot gripper.
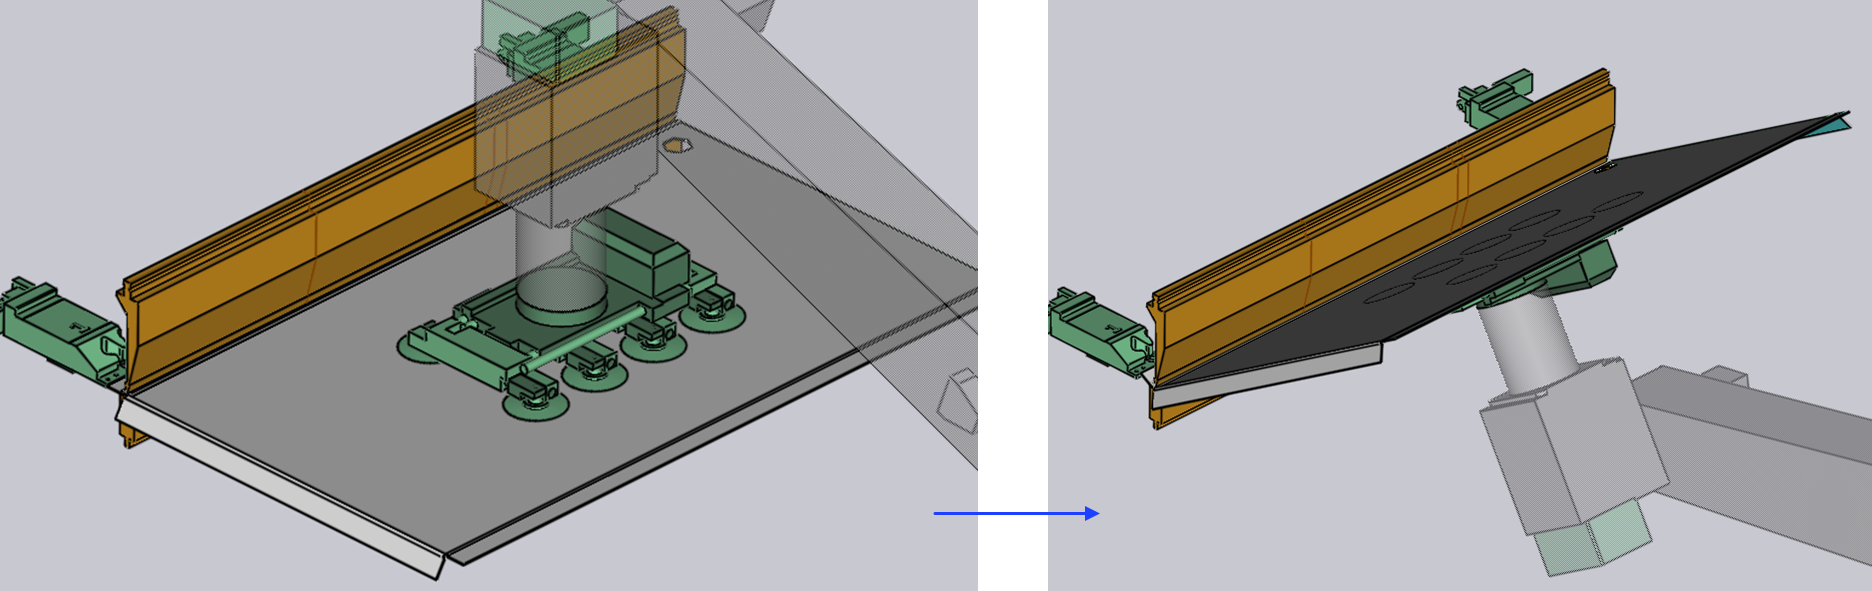
Edit Bend: This option appears when the During Bend method is selected. It allows you to modify the bend parameters of the current bend.
Post-Bend
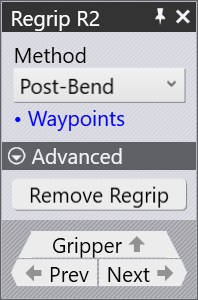
When the Post-Bend method is selected, the regripping happens after the bending process with the part still at the clamping point.
In this method, the robot gripper will assist the part during the bending operation. Once the bending operation is completed with expected results, the regripping operation will start.
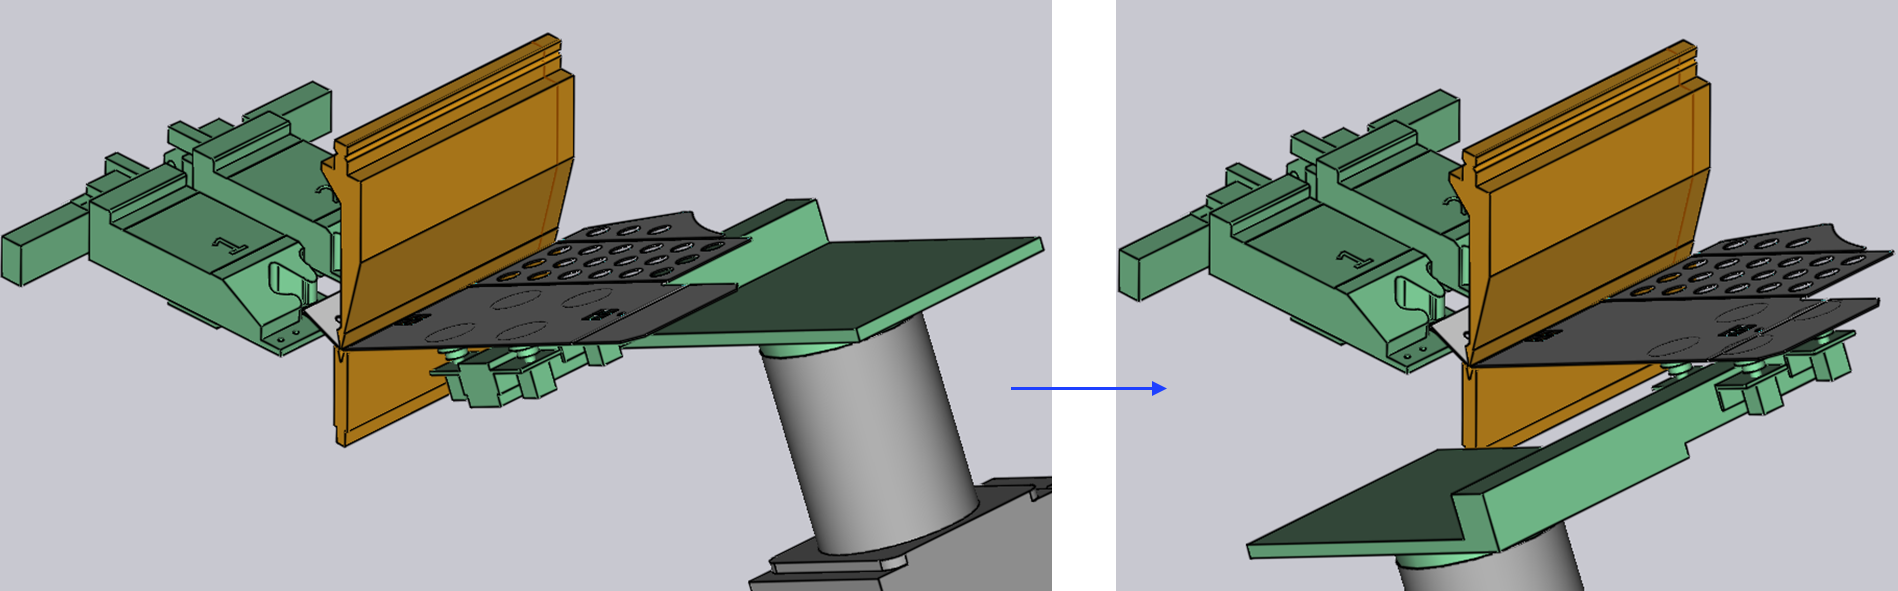
-
Waypoints: Opens the Waypoints panel for defining and managing the robot’s waypoints during the regripping operations.
Advanced
The Advanced section in the panel provides additional configuration options for regripping operations.
Remove regrip: This option allows you to remove an existing regrip operation. The details are explained in Add/Remove Regrip.