Part pickup
Part pickup is the first stage, where the robot lifts a flat blank from the Pickup pallet and positions it on a Centering table before bending.
Flex Cell CAM automatically selects the appropriate gripper based on part size
and the gripper inventory. When multiple grippers are suitable, the one with
the highest priority is chosen. If the required gripper is not in the inventory,
it can be imported from an .stl file via Database / Bend Grippers.
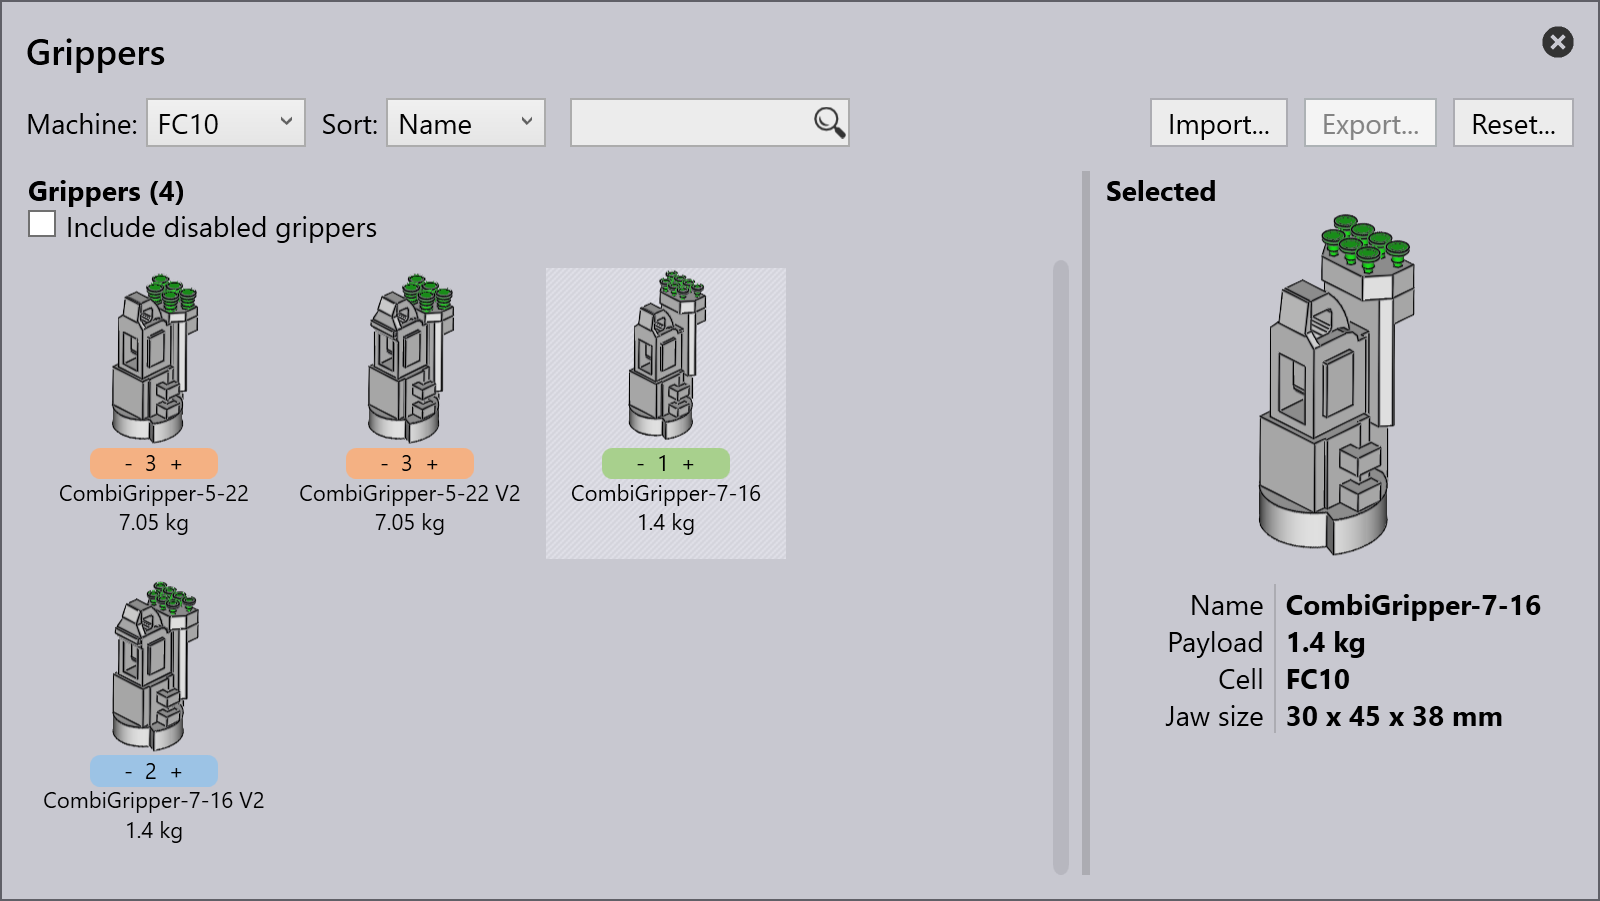
Frequently used grippers can be assigned a priority level (1 = Very High) in the database to influence automatic selection.
Combi gripper - a combination of Suction-type and Jaw-type gripper is used for pickup, deposit and bending operations.
-
Suction-type picks the blank from the Pickup pallet and places it on the Centering table.
-
Jaw-type takes the centered part from the Centering table, performs the bending sequence, and deposits the finished part.